×

| Category | Item | Specification Details |
|---|---|---|
| Basic Information | Product Model | A044 |
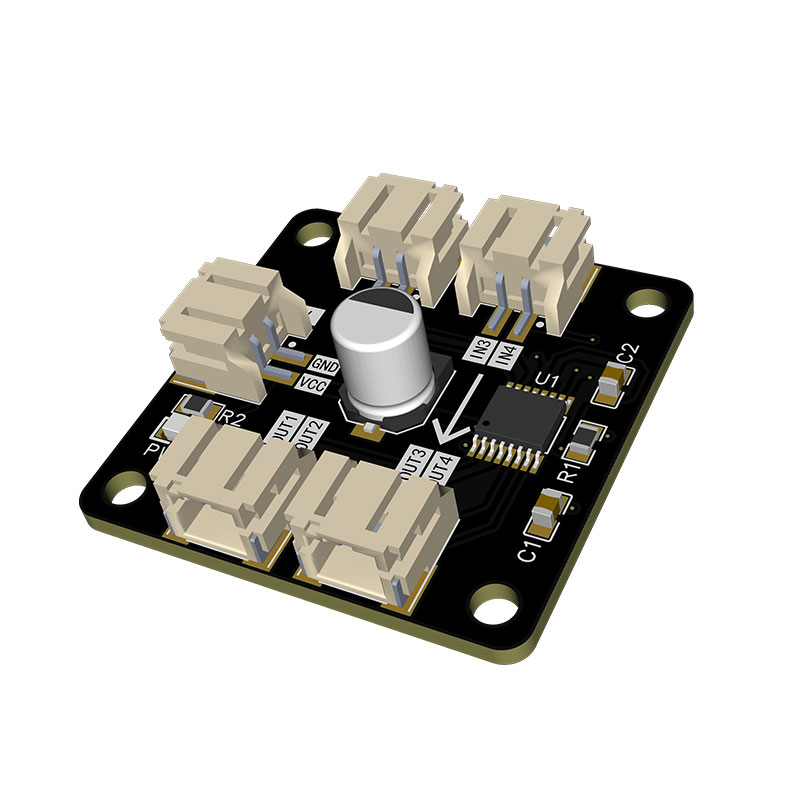
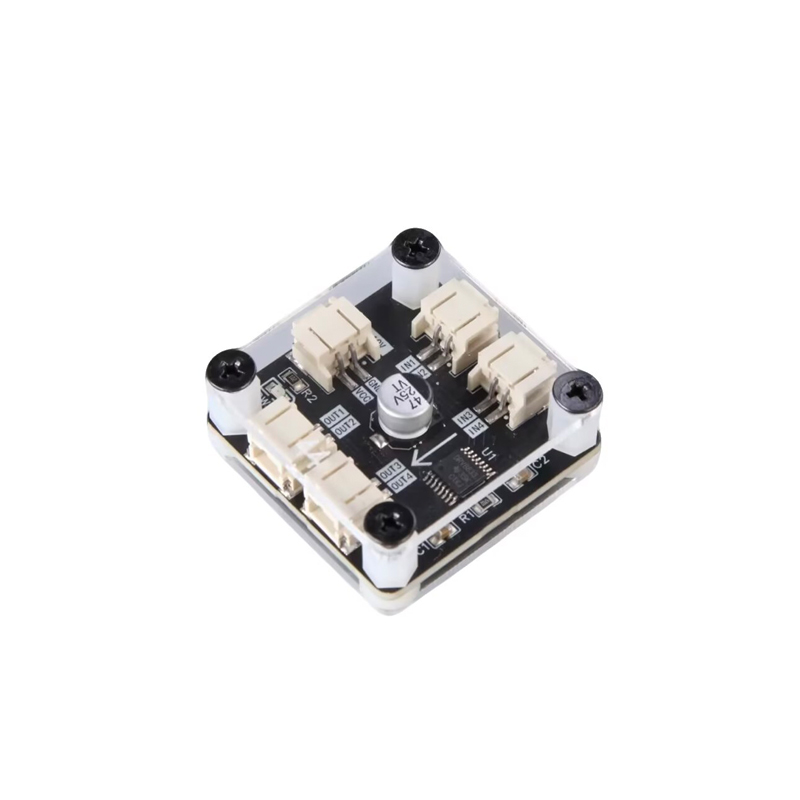
| Basic Information | Module Name | Dual‑Channel Motor Driver Module (A044) |
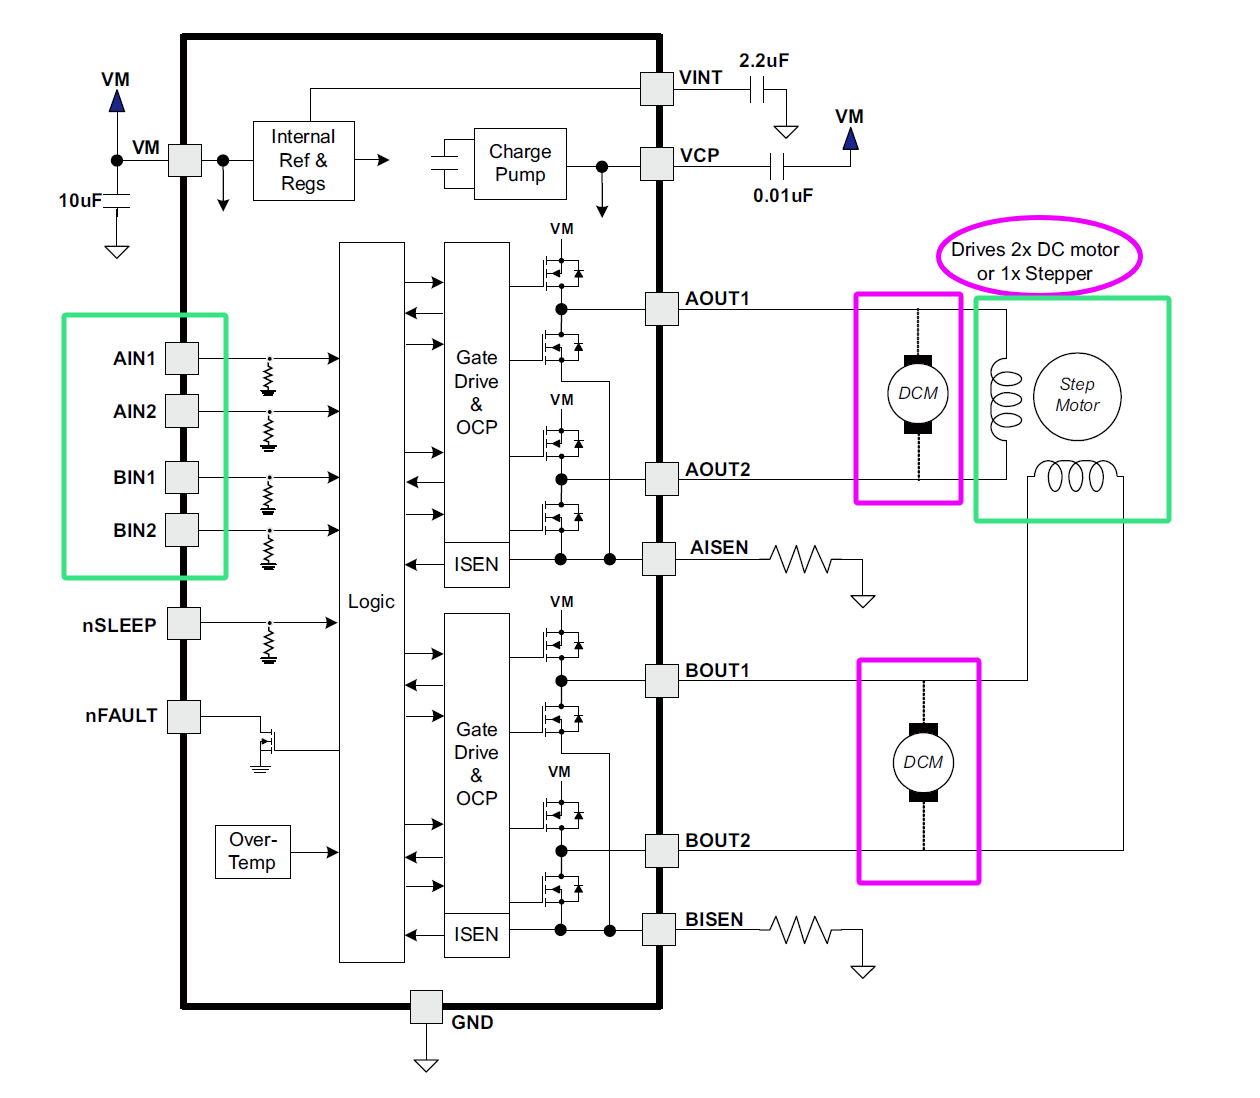
| Basic Information | Core Function | 2‑channel DC motor forward/reverse rotation, dynamic braking, PWM stepless speed regulation control |
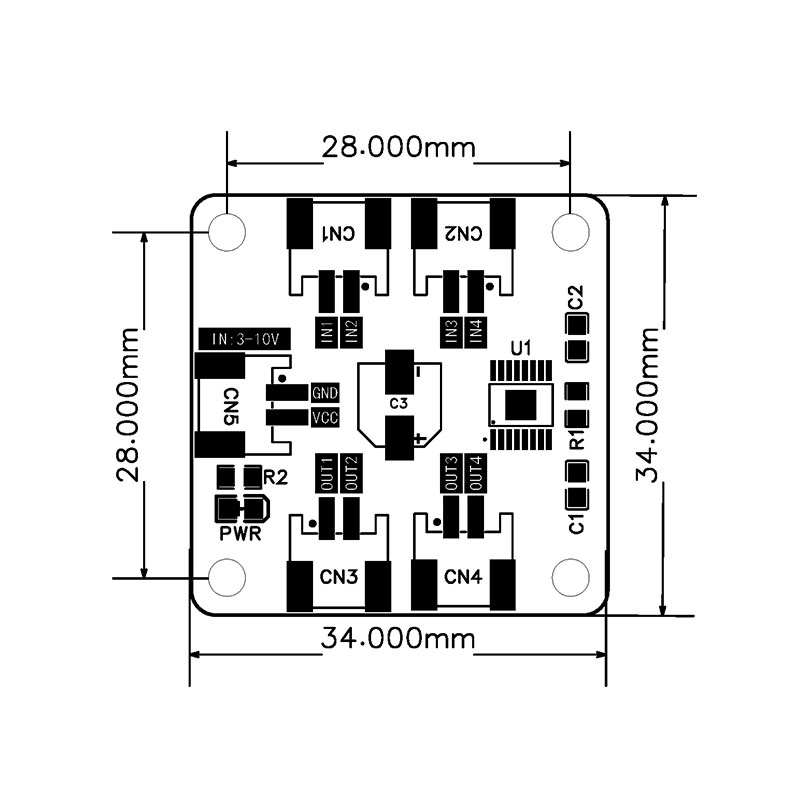
| Basic Information | PCB Dimension | 34.00mm × 34.00mm, 4 mounting holes reserved at four corners |
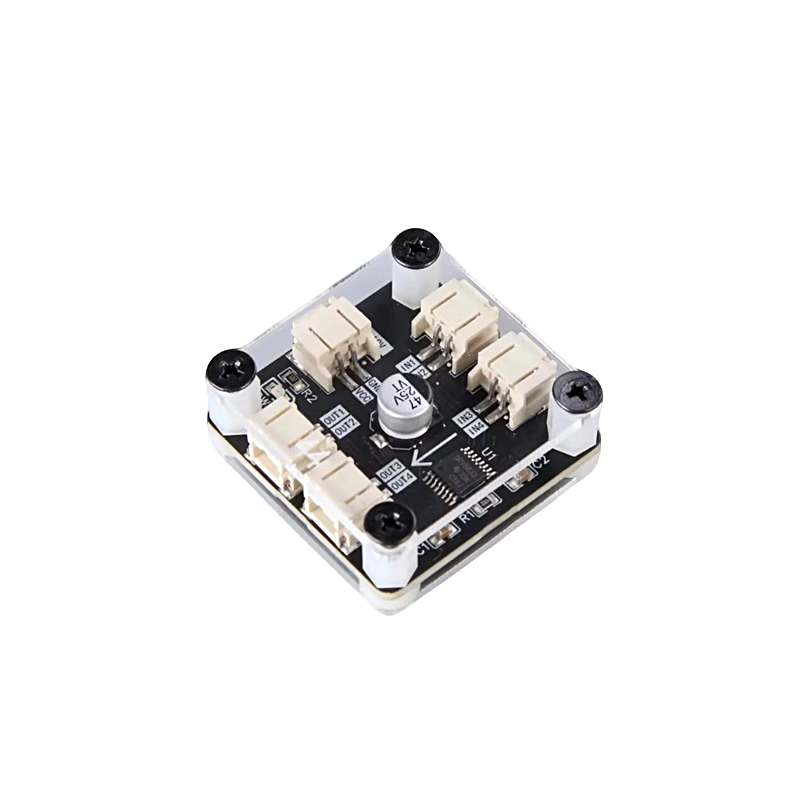
| Basic Information | Product Weight | Weight with enclosure: 15g; Bare‑board weight: 6g |
| Basic Information | Compatible Loads | TT/N20/N30 small DC geared motors, smart car chassis, miniature pan‑tilt |
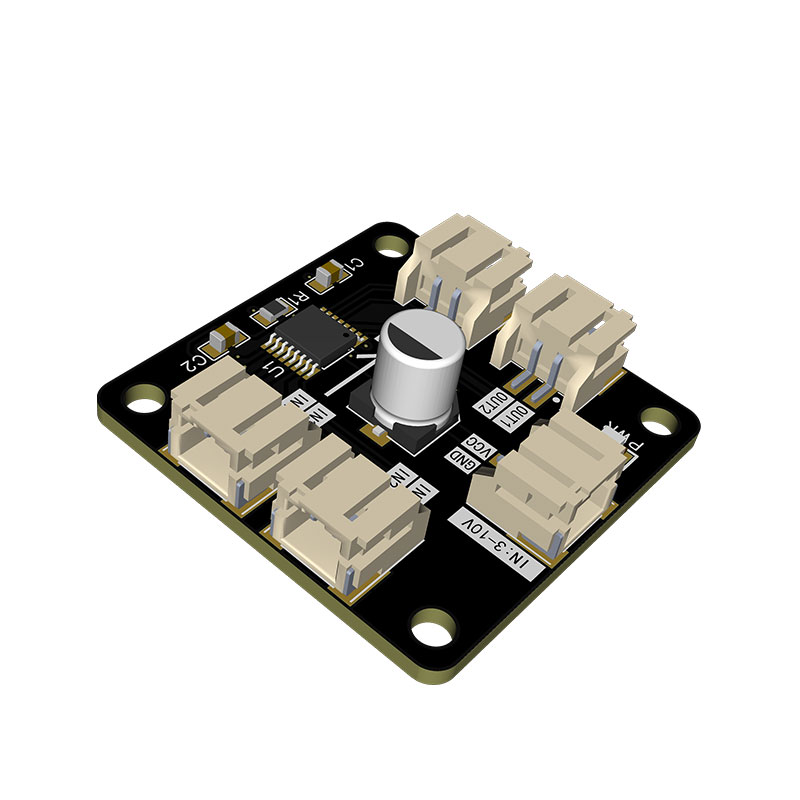
| Electrical Parameters | Motor Driving Power Supply | 3V~10V DC |
| Electrical Parameters | Logic Control Voltage | 3.3V~5V DC, compatible with Arduino/STM32/ESP32 MCUs |
| Electrical Parameters | Single‑Channel Continuous Output Current | Max 1.5A; higher peak current; heat sink required under heavy‑load conditions |
| Electrical Parameters | Control Logic Mode | Direct logic control via four IO ports IN1/IN2/IN3/IN4, supports PWM speed regulation |
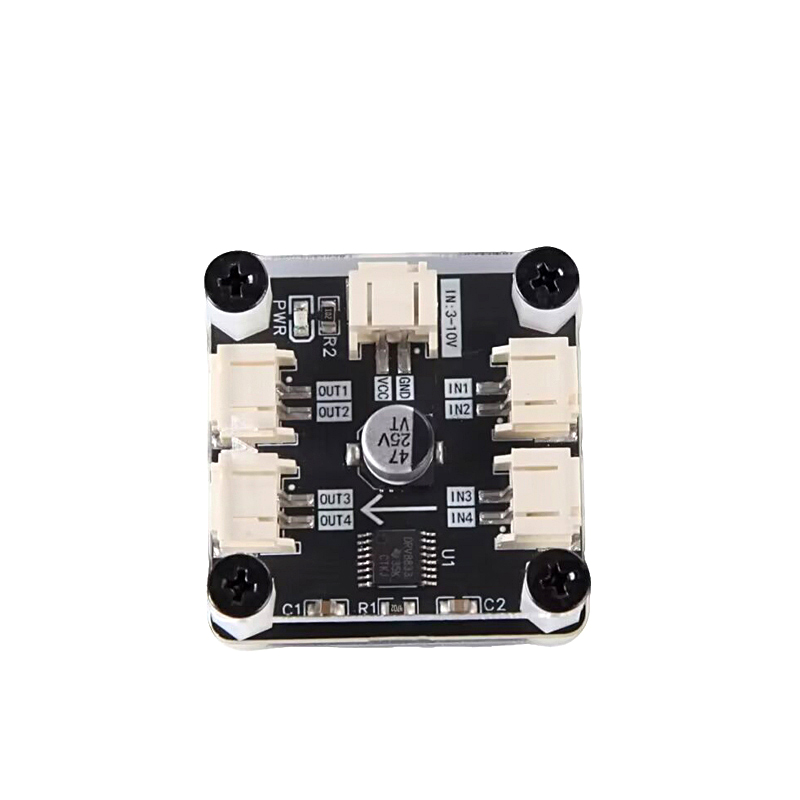
| On‑board Components | Core Chip | U1 H‑bridge driver chip |
| On‑board Components | Auxiliary Components | PWR power indicator LED, R1/R2 current‑limiting pull‑up resistors, C1/C2/C3 power‑supply filter capacitors |
| Control Interface CN5 Pin | GND | System common ground; must share ground with the MCU |
| Control Interface CN5 Pin | VCC | Positive terminal for logic power supply, connect to 3.3V/5V |
| Control Input Pins | IN1, IN2 | Logic control inputs for Motor 1, for direction and brake control |
| Control Input Pins | IN3, IN4 | Logic control inputs for Motor 2, for direction and brake control |
| Motor Output Terminals | OUT1, OUT2 (CN3/CN1) | Channel 1 motor outputs, connect directly to both terminals of the motor |
| Motor Output Terminals | OUT3, OUT4 (CN4/CN2) | Channel 2 motor outputs, connect directly to both terminals of the motor |
| Control Logic‑Forward Rotation | Channel1: IN1 High / IN2 Low; Channel2: IN3 High / IN4 Low | OUT1 positive & OUT2 negative; OUT3 positive & OUT4 negative |
| Control Logic‑Reverse Rotation | Channel1: IN1 Low / IN2 High; Channel2: IN3 Low / IN4 High | OUT1 negative & OUT2 positive; OUT3 negative & OUT4 positive |
| Control Logic‑Dynamic Braking | Channel1: IN1 High / IN2 High; Channel2: IN3 High / IN4 High | Short‑circuit both output terminals for braking |
| Control Logic‑Freewheeling | Channel1: IN1 Low / IN2 Low; Channel2: IN3 Low / IN4 Low | Motor power‑off with no drive, free coasting |
| Speed Regulation Method | Apply PWM pulses to IN1/IN2/IN3/IN4 inputs; adjust duty cycle to control motor speed | |
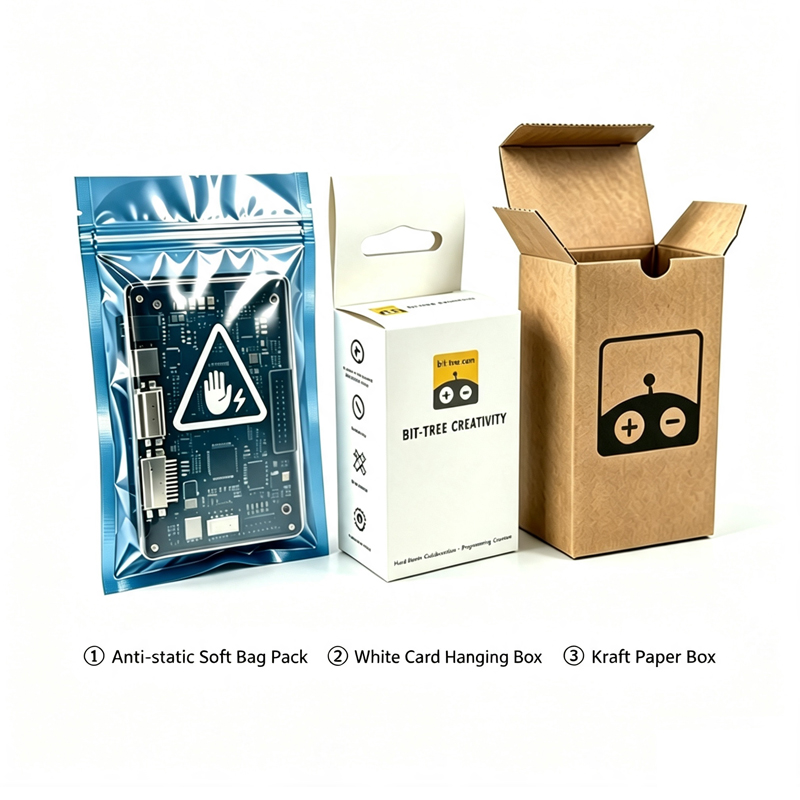
| Packaging Solution | Optional Packaging | ① Anti‑static bag soft package ② White card hanging blister box ③ Kraft paper carton |