×


| Parameter Category | Item | Specification Details |
|---|---|---|
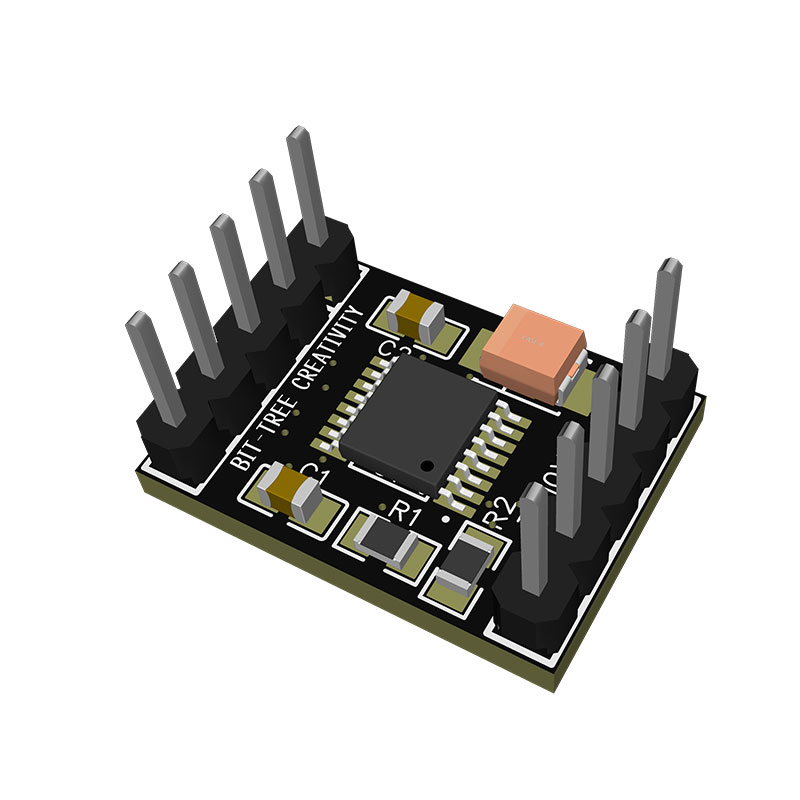
| Basic Information | Product Model | A043 |
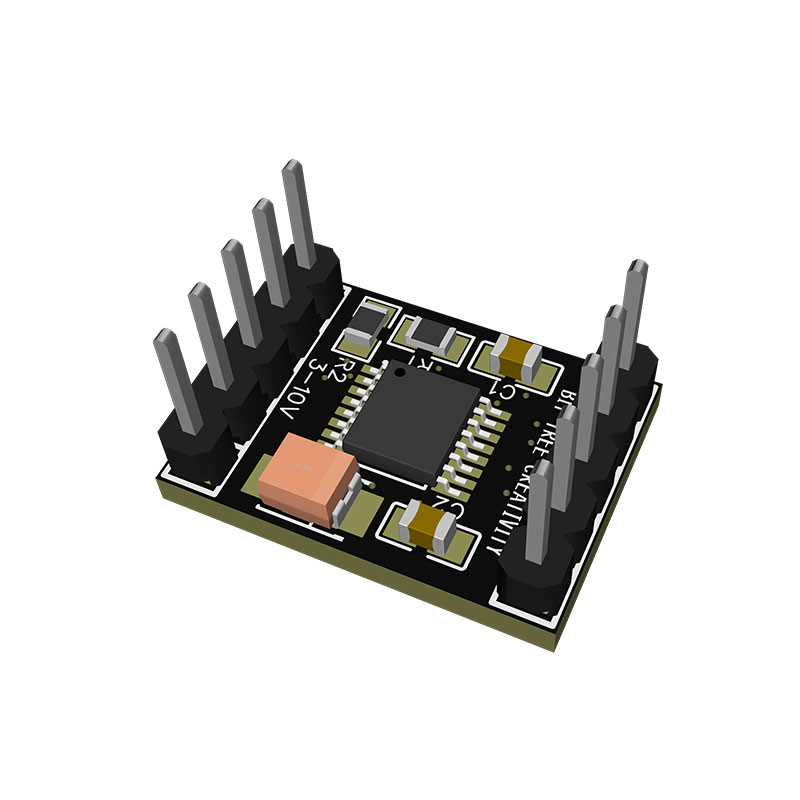
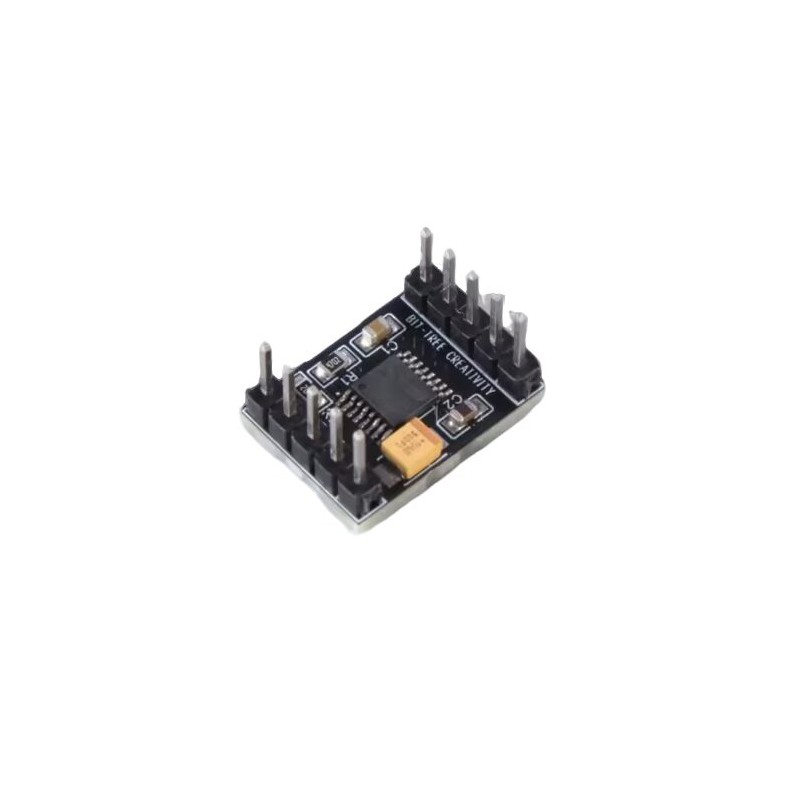
| Basic Information | Module Name | 2-Channel Motor Driver Module MINI (A043) |
| Basic Information | Core Functions | Control forward/reverse rotation of 2 DC motors, PWM stepless speed regulation |
| Basic Information | PCB Dimensions | 13.50mm × 18.50mm |
| Basic Information | Applicable Scenarios | TT/N20 small DC geared motors, micro smart cars, pan-tilt control |
| Basic Information | Product Weight | 1.6g |
| Electrical Parameters | Motor Supply Voltage | 3V~10V DC, compatible with 3.7V lithium battery power supply |
| Electrical Parameters | Logic Control Voltage | 3.3V~5V DC, compatible with MCUs such as Arduino/STM32/ESP32 |
| Electrical Parameters | Continuous Current per Channel | Max 1.5A, higher peak current; heat dissipation required under heavy load |
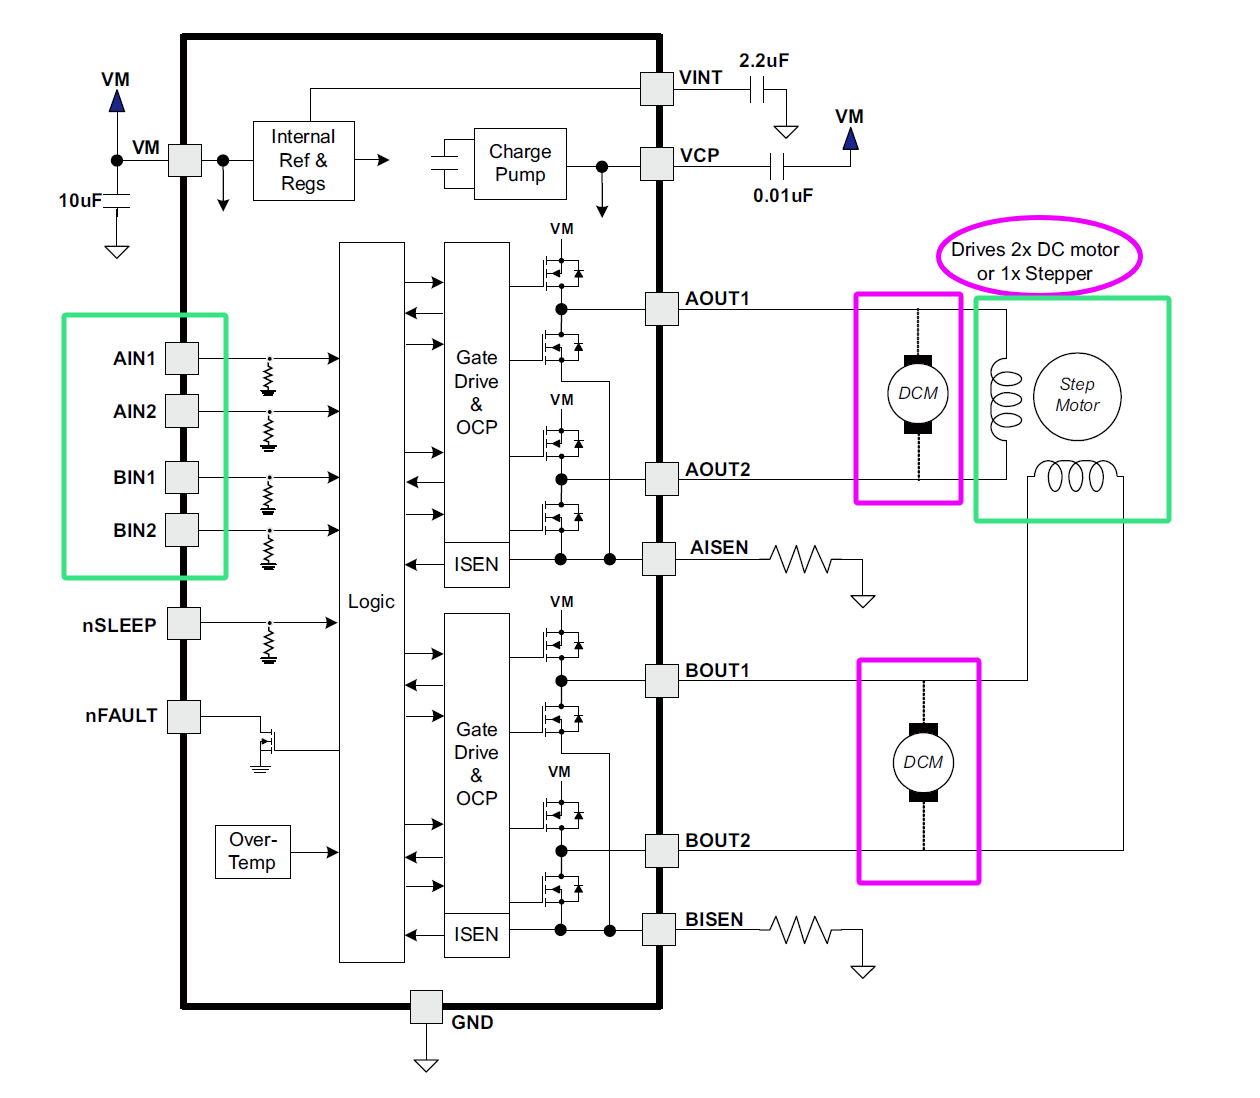
| Electrical Parameters | Control Method | 4-channel logic input via IN1/IN2/IN3/IN4, supports PWM speed regulation |
| Top Pin Definitions | VCC | Positive logic power supply pin, connect to 3.3V/5V |
| Top Pin Definitions | IN1 | Logic Input 1 for Motor 1, controls rotation direction and braking |
| Top Pin Definitions | IN2 | Logic Input 2 for Motor 1, cooperates with IN1 to control forward/reverse rotation |
| Top Pin Definitions | IN3 | Logic Input 1 for Motor 2, controls rotation direction and braking |
| Top Pin Definitions | IN4 | Logic Input 2 for Motor 2, cooperates with IN3 to control forward/reverse rotation |
| Bottom Pin Definitions | GND | Common power ground, must share ground with the MCU |
| Bottom Pin Definitions | OUT1 | Output A for Motor 1, connect to one terminal of the motor |
| Bottom Pin Definitions | OUT2 | Output B for Motor 1, connect to the other terminal of the motor |
| Bottom Pin Definitions | OUT3 | Output A for Motor 2, connect to one terminal of the motor |
| Bottom Pin Definitions | OUT4 | Output B for Motor 2, connect to the other terminal of the motor |
| Control Logic | Forward Rotation Control | IN1 High / IN2 Low, OUT1 positive output, OUT2 negative output |
| Control Logic | Reverse Rotation Control | IN1 Low / IN2 High, OUT1 negative output, OUT2 positive output |
| Control Logic | Braking Mode | IN1 High / IN2 High, short-circuit braking via OUT1 and OUT2 |
| Control Logic | Speed Regulation Method | Input PWM signals to IN1/IN2/IN3/IN4, adjust rotation speed by duty cycle |
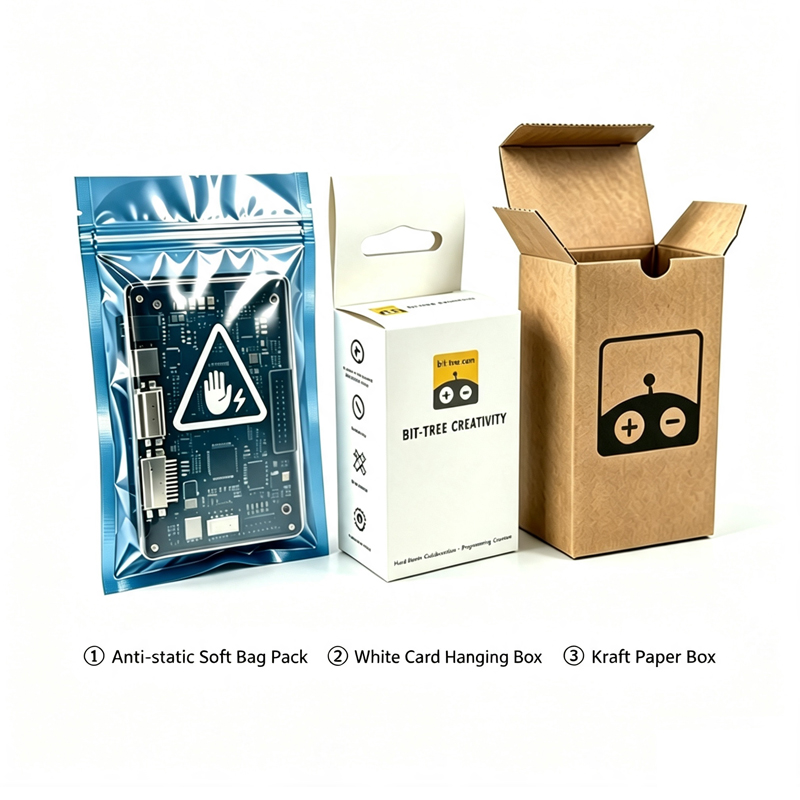
| Packaging Solutions | Optional Packaging | ① Anti-static bag soft package ② White cardboard hanging hole box ③ Kraft paper box |